Shubham Sonawani

Shubham Sonawani

Portrait of Shubham Sonawani

Robotics researcher focused on turning perception and learning methods into systems that work outside the lab. Experience spans autonomous manipulation for medical applications, vision-guided navigation across solar arrays, pose estimation for NASA's Mars Sample Return program, and human–robot interaction. I am a Research Scientist at Apricity Robotics, where I develop robot-learning and multimodal-perception systems for next-generation healthcare robots. I received my Ph.D. from Arizona State University, where I worked on human–robot interaction, robot learning, and computer vision in the Interactive Robotics Laboratory with Prof. Heni Ben Amor. Current interests include robot learning, multimodal learning for grasping and manipulation, teleoperation, computer vision, and safe human–robot interaction.

Latest

Updates

Mar 2026

Joined Apricity Robotics

Started at Apricity Robotics, building robot-learning policies for the NSF project Tele-Directed Artificially Intelligent Sonography Robot.
Aug 2025

Joined Erthos

Started as a Research Scientist at Erthos, working on robotics vision.

Jun 2024

Papers accepted at IROS 2024

Two papers accepted for presentation at IROS 2024.

Jan 2024

Paper accepted at ICRA 2024

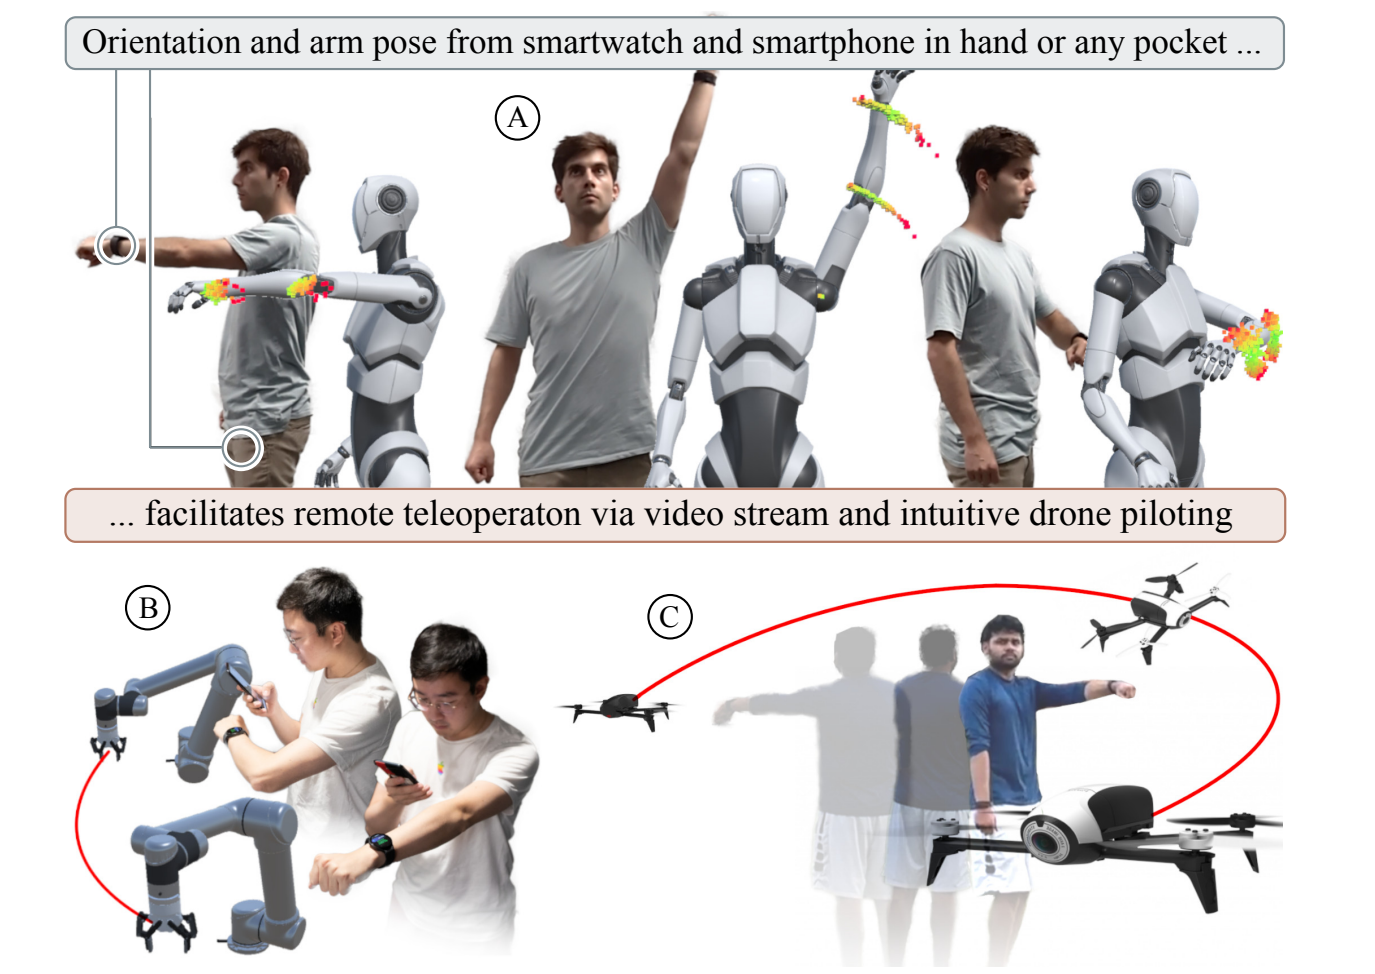
iRoCo: Intuitive Robot Control From Anywhere Using a Smartwatch was accepted at ICRA 2024.

Oct 2023

Open X-Embodiment collaboration

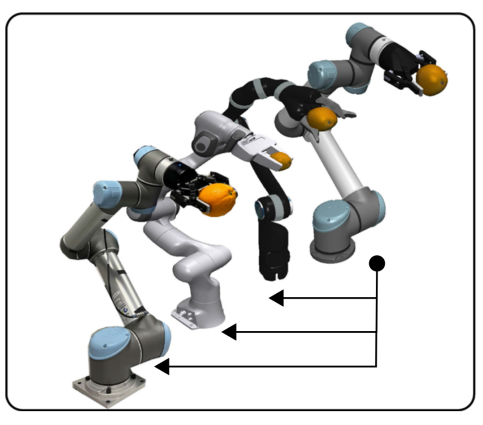
Part of the worldwide collaboration on Open X-Embodiment: Robotic Learning Datasets and RT-X Models.

Aug 2023

Article in Autonomous Robots

Learning modular language-conditioned robot policies through attention was accepted in Autonomous Robots.

Dec 2022

Paper accepted at CoRL 2022

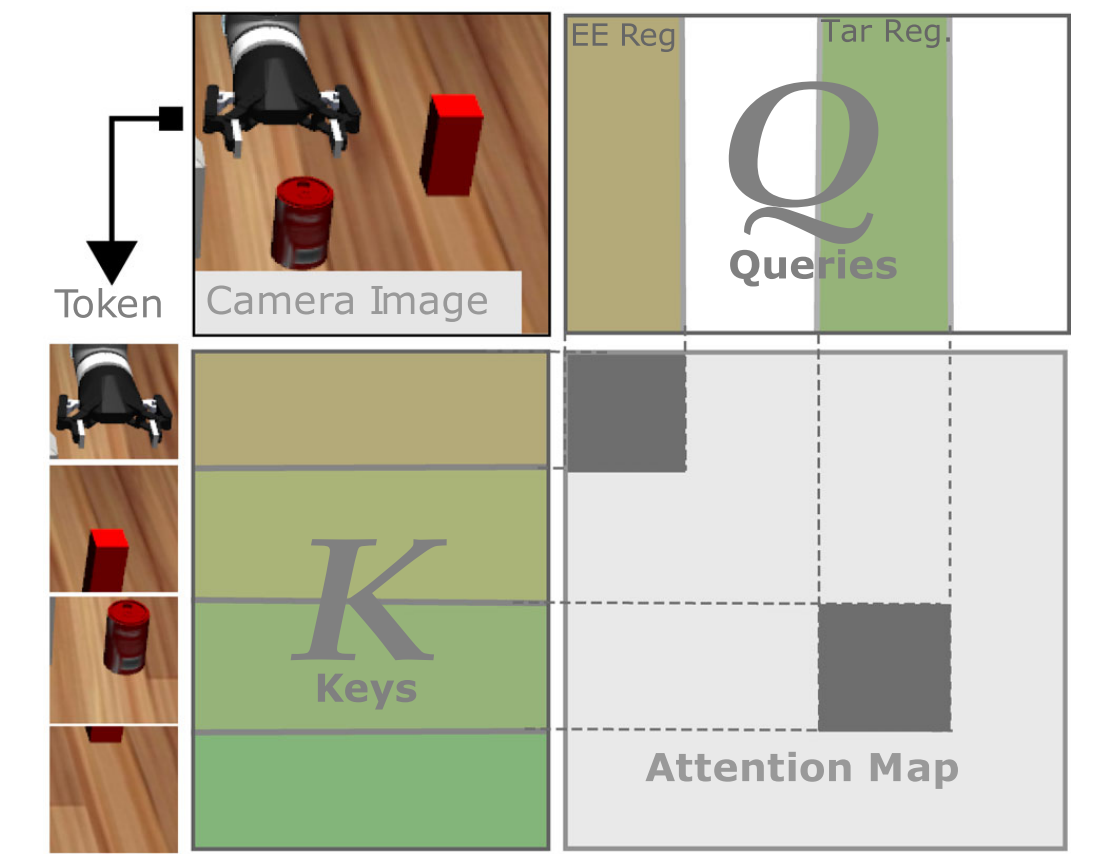
Modularity through attention: Efficient training and transfer of language-conditioned policies for robot manipulation was accepted at CoRL 2022.

Aug 2022

Workshop paper at XR-ROB

Imitation Learning based Auto-Correction of Extrinsic Parameters for A Mixed-Reality Setup was accepted at XR-ROB, IROS 2022.

Feb 2022

Workshop paper at VAM-HRI

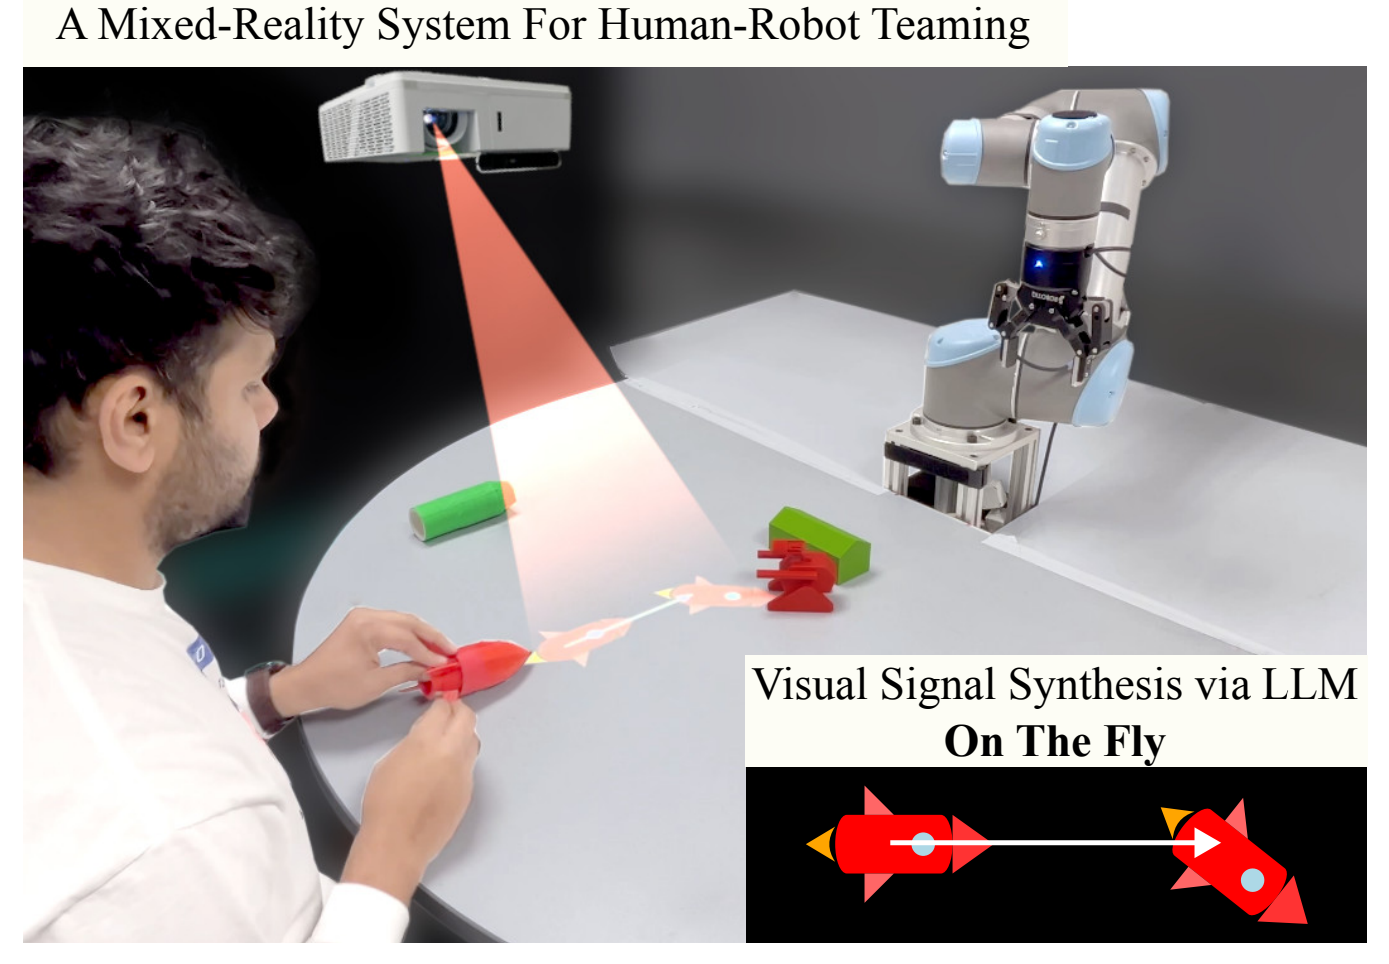
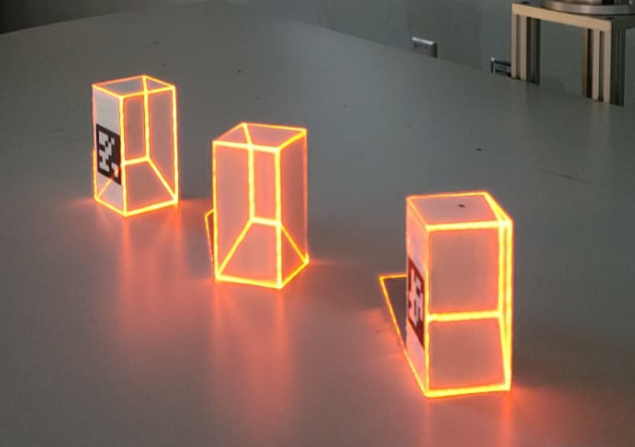
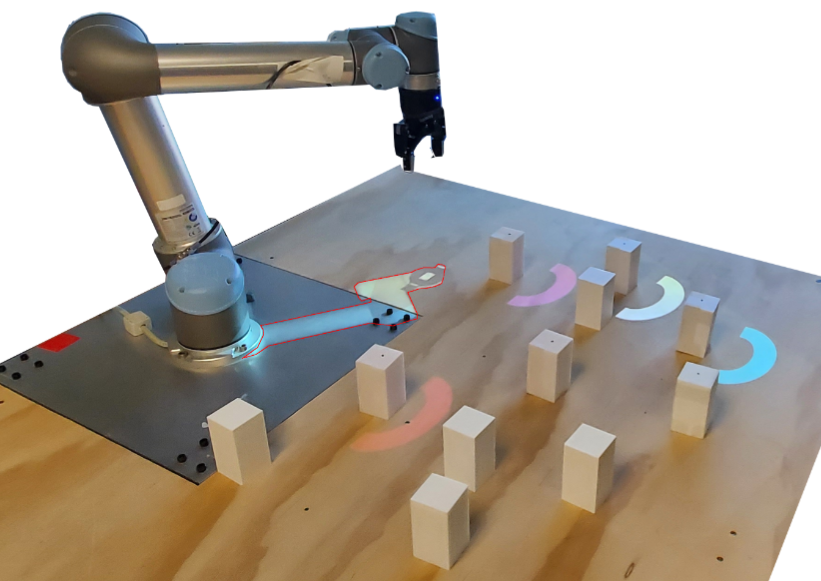
When And Where Are You Going? A Mixed-Reality Framework for Human Robot Collaboration was accepted at VAM-HRI 2022.

Practice

Work

  • Robot learning

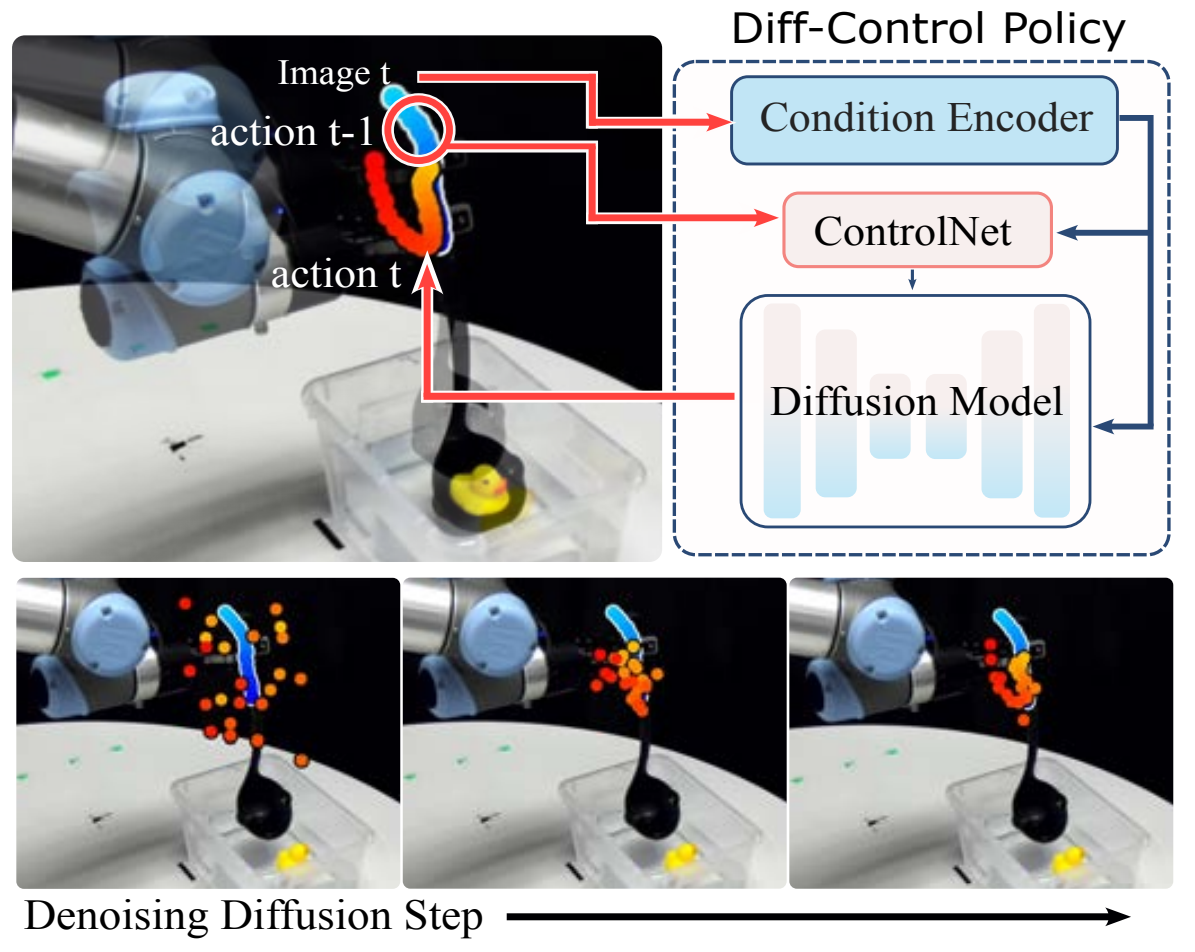
    Imitation learning, language-conditioned policies, and diffusion policies for manipulation.

  • Multimodal perception

    Vision, pose estimation, and sensor fusion for robots that have to perceive a messy world.

  • Human–robot interaction

    Visual signaling, mixed reality, and teleoperation so people can tell what a robot will do next.

  • Systems outside the lab

    Medical manipulation, solar-array navigation, and in-space assembly, not only benchmark tasks.

Research Scientist

Apricity Robotics

  • Building robot-learning policies for the NSF Tele-Directed Artificially Intelligent Sonography Robot.
  • Developing perception and manipulation for medical robotics.

Research Scientist, Robotics Vision

Erthos

  • Researched deep-learning semantic segmentation and lane detection for robotic traversal on solar panels.
  • Built computer-vision components with PyTorch, ROS 2, OpenCV, Python, and C++ for autonomous navigation on earth-mounted solar arrays.

R&D Intern, AI and Robotics

Erthos

  • Implemented a production robot-docking method combining computer vision and GPS.
  • Developed and tested the ROS and ROS 2 docking workflow in Gazebo using PyTorch, OpenCV, Python, C++, and C#.

Visiting Student Researcher

NASA Jet Propulsion Laboratory

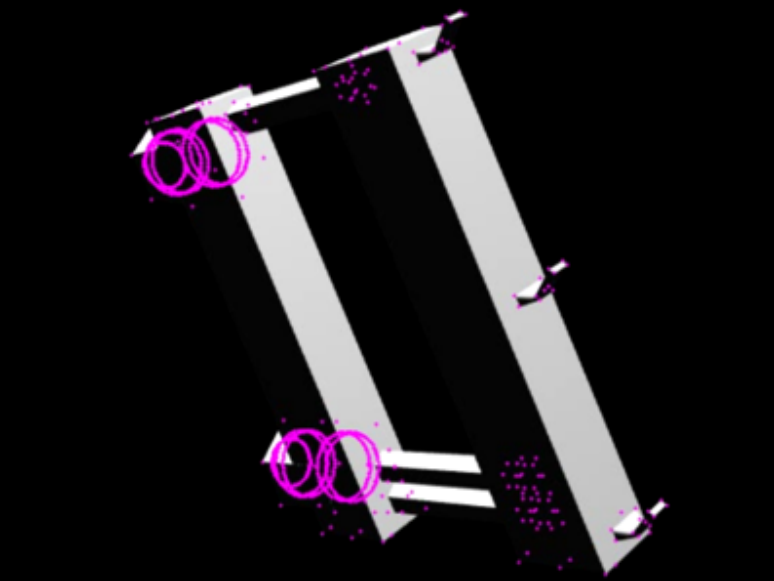
  • Investigated pose estimation methods for Mars Sample Return tubes.
  • Created robot-perception experiments using ROS, Gazebo, TensorFlow, OpenCV, C++, and Python.

Record

Research

Research Associate, Earth-Mounted Solar Robotics

Arizona State University and Erthos

  • Developed a ROS–Gazebo simulation environment for testing and verification.
  • Implemented semantic segmentation and lane detection models for the robot navigation stack.

Research Assistant, Autonomous In-Space Assembly

Arizona State University and NASA JPL

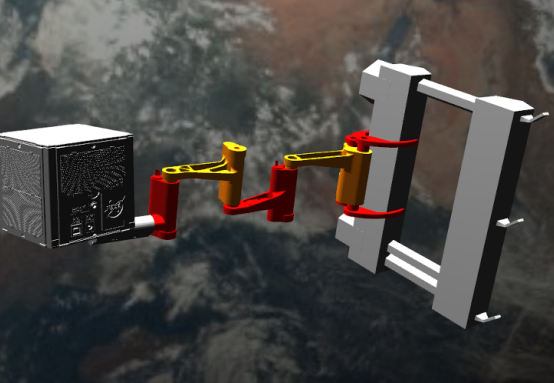
  • Implemented an optimized monocular vision tracking algorithm for object detection and tracking.
  • Demonstrated a real-world assembly task with the robotic system.

Research Assistant, Robotic Inventory Systems

Arizona State University and Intel

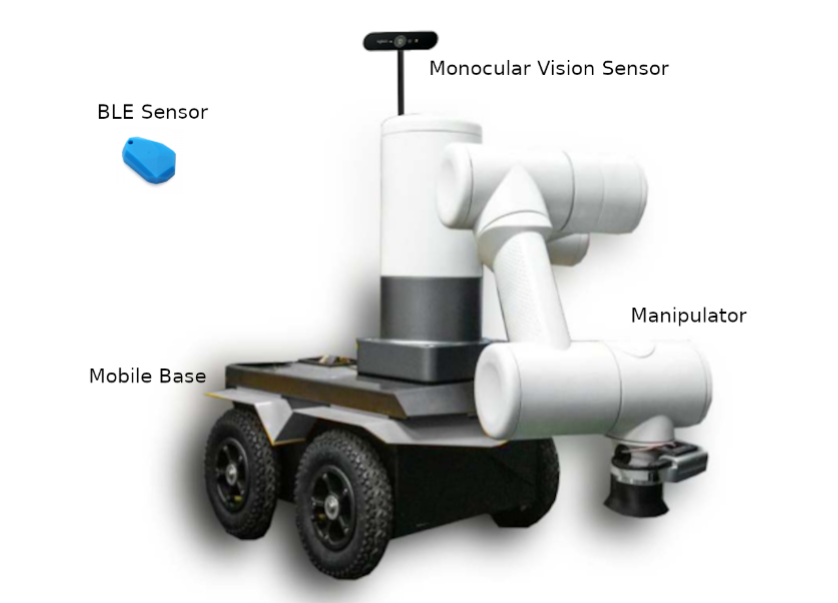
  • Developed a software stack connecting a custom robotic arm and a Clearpath Jackal mobile robot.
  • Improved SLAM accuracy for robotic inventory.

Education

Ph.D. in Electrical Engineering

Arizona State University

Thesis: Intelligent Visual Signaling for Mixed Reality-Based Human-Robot Interaction

M.S. in Electrical Engineering

Arizona State University

Thesis: Towards Next-Generation Mobile Manipulation and Grasping

B.Tech. in Electrical Engineering

Veermata Jijabai Technological Institute

Thesis: Passive Localization and Path Planning for an Ackermann-Drive Robot

Tools

Programming
PythonC++CC#JavaRJavaScript
Learning and vision
PyTorchTensorFlowOpenCVSemantic segmentationDetection and trackingPose estimationImitation learning
Robotics
ROSROS 2ManipulationNavigationSLAMLocalizationDockingTeleoperation
Simulation
Isaac SimGazeboMuJoCoUnityDocker

Published work

Papers

IROS · 2024

Shubham Sonawani, Fabian C. Weigend, Heni Ben Amor

IROS · 2024

Xiao Liu, Yifan Zhou, Fabian C. Weigend, Shubham Sonawani, Shuhei Ikemoto, Heni Ben Amor

ICRA · 2024

Fabian C. Weigend, Xiao Liu, Shubham Sonawani, Neelesh Kumar, Venugopal Vasudevan, Heni Ben Amor

ICRA · 2024

Open X-Embodiment Collaboration

IROS · 2023

Shubham Sonawani, Yifan Zhou, Heni Ben Amor

arXiv · 2023

Fabian C. Weigend, Shubham Sonawani, Michael Drolet, Heni Ben Amor

Autonomous Robots · 2023

Yifan Zhou, Shubham Sonawani, Mariano Phielipp, Heni Ben Amor, Simon Stepputtis

XR-ROB, IROS workshop · 2022

Shubham Sonawani, Yifan Zhou, Heni Ben Amor

CoRL · 2022

Yifan Zhou, Shubham Sonawani, Mariano Phielipp, Simon Stepputtis, Heni Ben Amor

VAM-HRI · 2022

Shubham Sonawani, Heni Ben Amor

arXiv · 2021

Shubham Sonawani, Kailas Maneparambil, Heni Ben Amor

AIAA · 2020

Shubham Sonawani, Ryan Alimo, Renaud Detry, Daniel Jeong, Andrew Hess, Heni Ben Amor

Manuscript · 2019

Shubham Sonawani, S. Kailas, R. Detry, R. Alimo, S. Backus, R. McCormick, R. Mukherjee, K. Wehage, Heni Ben Amor

CCTA · 2017

Armando A. Rodriguez, Karan Puttannaiah, ZhenYu Lin, Jesus Aldaco, Zhichao Li, Xianglong Lu, Kaustav Mondal, Shubham D. Sonawani, Nikhilesh Ravishankar, Nirangkush Das, and others

CCTA · 2017

Armando A. Rodriguez, Karan Puttannaiah, ZhenYu Lin, Jesus Aldaco, Zhichao Li, Xianglong Lu, Kaustav Mondal, Shubham D. Sonawani, Nikhilesh Ravishankar, Nirangkush Das, and others

Recognition

  • Best Conference Paper Award, ICRA 2024 — Open X-Embodiment
  • Best RoboCup Paper Award Finalist, IROS 2023
  • Best Poster Award, IROS 2023 XR-ROB Workshop
  • Best Poster Award, ICRA 2020 Space Robotics Workshop
  • Keen Research Grant

Reviewer for an ICRA 2024 workshop proposal and an IROS 2022 conference paper.

Student organizer for the ICRA 2021 Curiosity in Robots workshop.